!ORIENTATION
Defines a local coordinate system.
Parameters
When DEFINITION = COORDINATES
(2nd line) a1, a2, a3, b1, b2, b3, c1, c2, c3
| Variable | Type | Description |
|---|---|---|
| a1, a2, a3 | R | Global coordinates of point a |
| b1, b2, b3 | R | Global coordinates of point b |
| c1, c2, c3 | R | Global coordinates of point c |
When DEFINITION= NODES
(2nd line) a, b, c
| Variable | Type | Description |
|---|---|---|
| a, b, c | I | Node numbers |
When DEFINITION = LOCAL_NODES
(2nd line) a, b, c
| Variable | Type | Description |
|---|---|---|
| a, b, c | I | Local node numbers within the element |
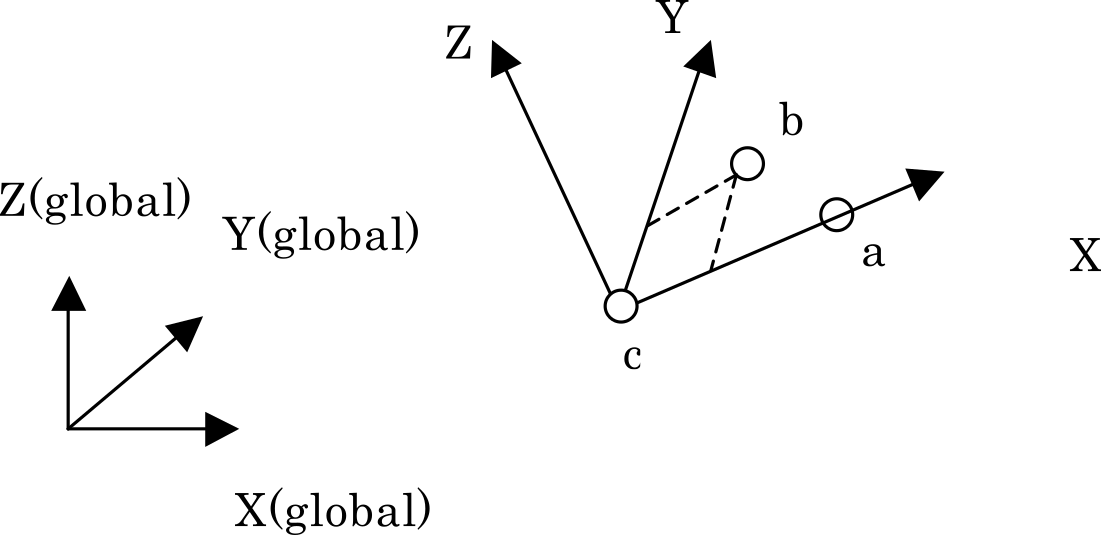
For each element, a local coordinate system is defined from the coordinates of nodes a, b, and c of that element. The relationship between a, b, c and the coordinate axes is shown in the figure. Because the local coordinate system can have a different orientation for each element, this specification is used to assign the material principal axes of an anisotropic material along the element shape. The local coordinate system is evaluated from the deformed nodal coordinates, so it follows the rotation and deformation of the element.
- All three of a, b, and c must be specified. If any is omitted, an error occurs and the analysis stops.
- Local node numbers must be between 1 and 10 and must not exceed the number of nodes in the target element.
Example
When defining a local coordinate system from local nodes 5, 1, and 8 of each element and applying it to the section with SECNUM=1